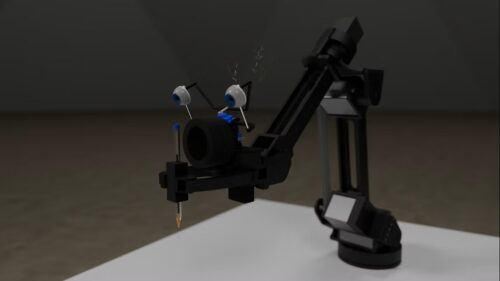
Anna Frants, with the participation of CYLAND MediaArtLab
Installation, 2025
C, Python, Arduino, and Raspberry PI boards, stepper and servo motors, web camera, microphone, PLA plastic
Engineers: Philipp Avetisov, Eugene Ovsyannikov, Dmitry Shirokov, Maxim Lukin
Technical Description: The Robot is driven by stepper motors that define the primary trajectories of its movement. Control is implemented through a combination of Arduino and Raspberry Pi, with software developed in C++ and Python. For data input, the system employs a wide-angle digital camera, a microphone, and an ultrasonic sensor. Output devices include a paper-feed mechanism, the robot’s “eyes” mounted on a servo drive, and an optional display.
Different Robot by Anna Frants features Anatoly, a robot-hand that reacts to variations in voice volume and speech, translating sound into movement. Through these spontaneous interactions, the work proposes that creativity can arise from algorithmic responsiveness and chance.
Participation in Exhibitions
Robot-in-the-Loop: Interactive Media Installations, CYFEST: Midpoint, Institute for Contemporary Art (ICA Yerevan), Yerevan, Armenia (19–25 October 2025).
Related Publications
Enrico Dedin, CYLAND: Media Art as an Active Principle — econique.art, 30 June 2026
Enrico Dedin, Interview with Anna Frants — Artribune, 5 September 2026